#include <any>#include <memory>#include <optional>#include <set>#include <string>#include <string_view>#include <utility>#include <vector>#include <wpi/commands2/SubsystemBase.hpp>#include <wpi/math/controller/ArmFeedforward.hpp>#include <wpi/math/controller/ElevatorFeedforward.hpp>#include <wpi/math/controller/SimpleMotorFeedforward.hpp>#include <wpi/math/system/DCMotor.hpp>#include <wpi/math/trajectory/ExponentialProfile.hpp>#include <wpi/math/trajectory/TrapezoidProfile.hpp>#include <wpi/units/acceleration.hpp>#include <wpi/units/angle.hpp>#include <wpi/units/angular_acceleration.hpp>#include <wpi/units/angular_jerk.hpp>#include <wpi/units/angular_velocity.hpp>#include <wpi/units/current.hpp>#include <wpi/units/force.hpp>#include <wpi/units/length.hpp>#include <wpi/units/mass.hpp>#include <wpi/units/moment_of_inertia.hpp>#include <wpi/units/temperature.hpp>#include <wpi/units/time.hpp>#include <wpi/units/velocity.hpp>#include <wpi/units/voltage.hpp>#include "yams/gearing/MechanismGearing.hpp"#include "yams/math/LQRConfig.hpp"
Include dependency graph for SmartMotorControllerConfig.hpp:

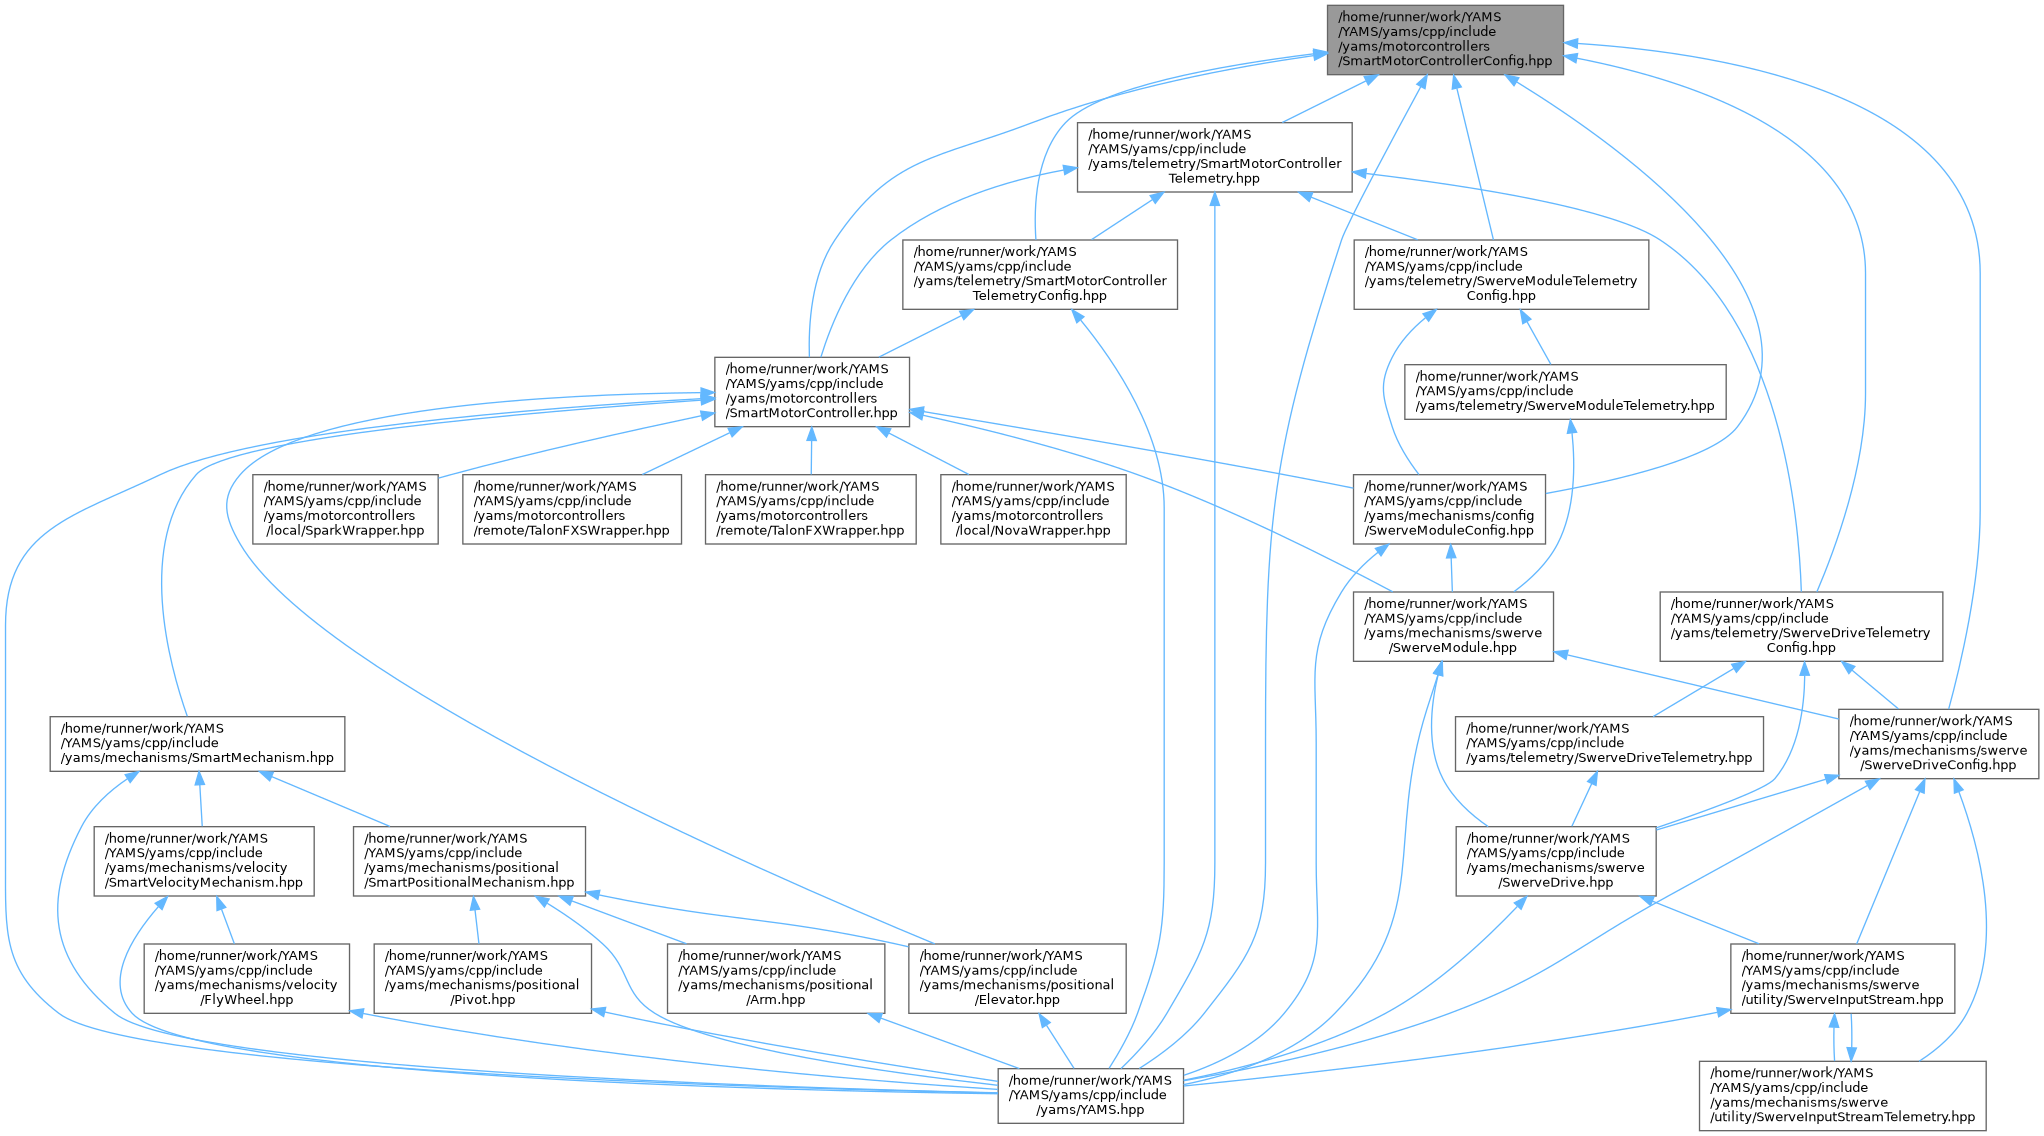
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Classes | |
| class | yams::motorcontrollers::SmartMotorControllerConfig |
| struct | yams::motorcontrollers::SmartMotorControllerConfig::PIDGains |
Namespaces | |
| namespace | yams |
| namespace | yams::motorcontrollers |
| namespace | yams::telemetry |
Typedefs | |
| using | yams::motorcontrollers::meters_per_second_cubed_t = wpi::units::unit_t< wpi::units::compound_unit< wpi::units::meters, wpi::units::inverse< wpi::units::cubed< wpi::units::seconds > > > > |
