#include <cassert>#include <cstdio>#include <functional>#include <optional>#include <span>#include <stdexcept>#include <string>#include <utility>#include <vector>#include <wpi/commands2/CommandPtr.hpp>#include <wpi/commands2/Commands.hpp>#include <wpi/framework/RobotBase.hpp>#include <wpi/math/estimator/SwerveDrivePoseEstimator.hpp>#include <wpi/math/geometry/Pose2d.hpp>#include <wpi/math/geometry/Rotation2d.hpp>#include <wpi/math/geometry/Rotation3d.hpp>#include <wpi/math/geometry/Translation2d.hpp>#include <wpi/math/geometry/Twist2d.hpp>#include <wpi/math/kinematics/ChassisVelocities.hpp>#include <wpi/math/kinematics/SwerveDriveKinematics.hpp>#include <wpi/math/kinematics/SwerveModulePosition.hpp>#include <wpi/math/kinematics/SwerveModuleVelocity.hpp>#include <wpi/math/kinematics/struct/ChassisVelocitiesStruct.hpp>#include <wpi/nt/NetworkTableInstance.hpp>#include <wpi/smartdashboard/Field2d.hpp>#include <wpi/system/Timer.hpp>#include <wpi/tunables/Tunables.hpp>#include <wpi/units/angle.hpp>#include <wpi/units/force.hpp>#include <wpi/units/length.hpp>#include <wpi/units/math.hpp>#include <wpi/units/time.hpp>#include <wpi/units/velocity.hpp>#include <wpi/util/array.hpp>#include "yams/exceptions.hpp"#include "yams/mechanisms/swerve/SwerveDriveConfig.hpp"#include "yams/mechanisms/swerve/SwerveModule.hpp"#include "yams/telemetry/MechanismTelemetry.hpp"#include "yams/telemetry/NetworkTablesBackends.hpp"#include "yams/telemetry/SwerveDriveTelemetry.hpp"#include "yams/telemetry/SwerveDriveTelemetryConfig.hpp"
Include dependency graph for SwerveDrive.hpp:

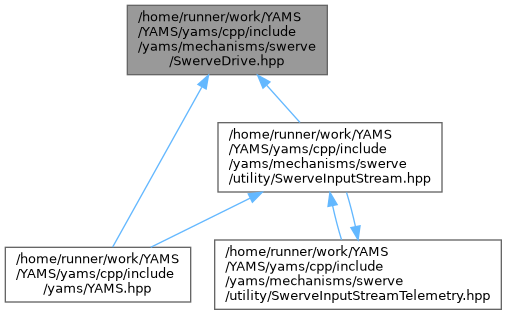
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Classes | |
| class | yams::mechanisms::swerve::SwerveDrive< NumModules > |
Namespaces | |
| namespace | yams |
| namespace | yams::mechanisms |
| namespace | yams::mechanisms::swerve |
| namespace | yams::telemetry |
