#include <SwerveModuleVelocityWithAzimuth.hpp>
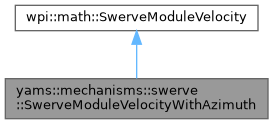
Inheritance diagram for yams::mechanisms::swerve::SwerveModuleVelocityWithAzimuth:
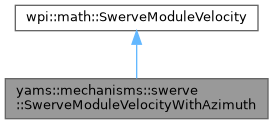
Collaboration diagram for yams::mechanisms::swerve::SwerveModuleVelocityWithAzimuth:
Public Member Functions | |
| SwerveModuleVelocityWithAzimuth ()=default | |
| SwerveModuleVelocityWithAzimuth (wpi::units::meters_per_second_t velocity, wpi::math::Rotation2d angle, wpi::units::radians_per_second_t azimuthVelocity) | |
Static Public Member Functions | |
| static wpi::math::SwerveModuleVelocity | Optimize (const wpi::math::SwerveModuleVelocity &desired, const SwerveModuleVelocityWithAzimuth &measured, const std::optional< wpi::math::Rotation2d > &lastCommanded, wpi::units::degree_t hysteresis=wpi::units::degree_t{30}) |
Public Attributes | |
| wpi::units::radians_per_second_t | azimuthVelocity {0} |
Detailed Description
A swerve module velocity that also carries how fast the azimuth is turning.
Constructor & Destructor Documentation
◆ SwerveModuleVelocityWithAzimuth() [1/2]
|
default |
◆ SwerveModuleVelocityWithAzimuth() [2/2]
|
inline |
- Parameters
-
velocity Wheel velocity. angle Azimuth angle. azimuthVelocity How fast the azimuth is turning.
Member Function Documentation
◆ Optimize()
|
inlinestatic |
Optimize a desired state against the measured one, keeping the orientation the wheel was last sent to unless the other is better by more than the hysteresis. Without it a wheel that is still turning reverses back and forth as the target moves across the 90 degree boundary.
- Parameters
-
desired Desired state. measured Measured state. lastCommanded Angle the wheel was last sent to, if any. hysteresis How much better the other orientation must be before the wheel reverses.
- Returns
- The optimized state.
Member Data Documentation
◆ azimuthVelocity
| wpi::units::radians_per_second_t yams::mechanisms::swerve::SwerveModuleVelocityWithAzimuth::azimuthVelocity {0} |
How fast the azimuth is turning.
The documentation for this struct was generated from the following file:
- /home/runner/work/YAMS/YAMS/yams/cpp/include/yams/mechanisms/swerve/SwerveModuleVelocityWithAzimuth.hpp
