#include <Elevator.hpp>
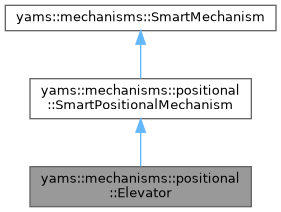
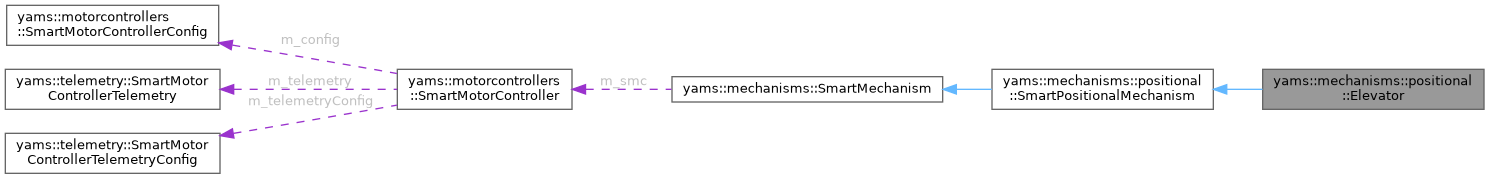
Public Member Functions | |
| Elevator (config::ElevatorConfig *config, motorcontrollers::SmartMotorController *smc) | |
| void | SimIterate () override |
| void | UpdateTelemetry () override |
| void | VisualizationUpdate () override |
| std::string | GetName () const override |
| wpi::cmd::Trigger | Max () override |
| wpi::cmd::Trigger | Min () override |
| wpi::cmd::CommandPtr | Run (wpi::units::meter_t height) |
| wpi::cmd::CommandPtr | Run (std::function< wpi::units::meter_t()> height) |
| wpi::cmd::CommandPtr | RunTo (wpi::units::meter_t height, wpi::units::meter_t tolerance=wpi::units::meter_t{0.01}) |
| wpi::cmd::CommandPtr | RunTo (std::function< wpi::units::meter_t()> height, wpi::units::meter_t tolerance=wpi::units::meter_t{0.01}) |
| wpi::units::meter_t | GetHeight () const |
| wpi::cmd::Trigger | Gte (wpi::units::meter_t height) |
| wpi::cmd::Trigger | Lte (wpi::units::meter_t height) |
| wpi::cmd::Trigger | Between (wpi::units::meter_t start, wpi::units::meter_t end) |
| wpi::cmd::Trigger | IsNear (wpi::units::meter_t height, wpi::units::meter_t within=wpi::units::meter_t{0.01}) |
| const config::ElevatorConfig & | GetConfig () const |
| wpi::math::Pose3d | GetPose3d () const override |
| std::vector< wpi::math::Pose3d > | GetCascadePose3d () const |
| std::vector< wpi::math::Pose3d > | GetContinuousPose3d (bool carriageFirst) const |
| void | SetHeight (wpi::units::meter_t height) |
 Public Member Functions inherited from yams::mechanisms::positional::SmartPositionalMechanism | |
| SmartPositionalMechanism () | |
| virtual | ~SmartPositionalMechanism ()=default |
| wpi::MechanismLigament2d * | GetMechanismLigament () |
| wpi::MechanismRoot2d * | GetMechanismRoot () |
| motorcontrollers::SmartMotorController * | GetMotor () |
| Public Member Functions inherited from yams::mechanisms::SmartMechanism | |
| SmartMechanism () | |
| virtual | ~SmartMechanism ()=default |
| wpi::cmd::CommandPtr | Set (double dutycycle) |
| wpi::cmd::CommandPtr | Set (std::function< double()> dutycycle) |
| wpi::cmd::CommandPtr | SetVoltage (wpi::units::volt_t volts) |
| wpi::cmd::CommandPtr | SetVoltage (std::function< wpi::units::volt_t()> volts) |
| void | SetMechanismVelocitySetpoint (wpi::units::turns_per_second_t velocity) |
| void | SetMeasurementVelocitySetpoint (wpi::units::meters_per_second_t velocity) |
| void | SetMechanismPositionSetpoint (wpi::units::turn_t angle) |
| void | SetMeasurementPositionSetpoint (wpi::units::meter_t distance) |
| void | SetVoltageSetpoint (wpi::units::volt_t voltage) |
| void | SetDutyCycleSetpoint (double dutycycle) |
| motorcontrollers::SmartMotorController * | GetMotorController () |
| std::optional< wpi::units::turn_t > | GetMechanismSetpoint () |
| std::optional< wpi::units::meter_t > | GetMeasurementSetpoint () |
| wpi::Mechanism2d * | GetMechanismWindow () |
Additional Inherited Members | |
| Protected Attributes inherited from yams::mechanisms::positional::SmartPositionalMechanism | |
| wpi::MechanismRoot2d * | m_mechanismRoot {nullptr} |
| wpi::MechanismLigament2d * | m_mechanismLigament {nullptr} |
| Protected Attributes inherited from yams::mechanisms::SmartMechanism | |
| wpi::cmd::SubsystemBase * | m_subsystem {nullptr} |
| motorcontrollers::SmartMotorController * | m_smc {nullptr} |
| std::optional< wpi::Mechanism2d > | m_mechanismWindow |
Detailed Description
Smart mechanism implementation for a linear elevator.
Drives a carriage along a linear axis using a SmartMotorController configured for measurement-space (meter) closed-loop control.
Example usage (inside a subsystem constructor)
Constructor & Destructor Documentation
◆ Elevator()
| yams::mechanisms::positional::Elevator::Elevator | ( | config::ElevatorConfig * | config, |
| motorcontrollers::SmartMotorController * | smc | ||
| ) |
Member Function Documentation
◆ Between()
| wpi::cmd::Trigger yams::mechanisms::positional::Elevator::Between | ( | wpi::units::meter_t | start, |
| wpi::units::meter_t | end | ||
| ) |
Trigger that fires while the elevator height is between start and end (inclusive).
- Parameters
-
start Lower bound. end Upper bound.
- Returns
- Trigger for the range condition.
◆ GetCascadePose3d()
| std::vector< wpi::math::Pose3d > yams::mechanisms::positional::Elevator::GetCascadePose3d | ( | ) | const |
Get the pose of each moving stage of a cascade elevator, for publishing to AdvantageScope as components of a robot model. A cascade elevator's stages all move at once, each by its share of the carriage's height: a stage that travels a third of the elevator's total travel moves a third of the carriage's height relative to the stage below it.
The stages are set with ElevatorConfig::WithStages().
- Returns
- Each moving stage's pose, relative to the robot, from the stage nearest the fixed stage to the carriage. The last is the carriage, GetPose3d().
- Exceptions
-
ElevatorConfigurationException if the stages are not set, or there are fewer than 2.
◆ GetConfig()
| const config::ElevatorConfig & yams::mechanisms::positional::Elevator::GetConfig | ( | ) | const |
Get the configuration used to construct this elevator.
- Returns
- Const reference to the ElevatorConfig.
◆ GetContinuousPose3d()
| std::vector< wpi::math::Pose3d > yams::mechanisms::positional::Elevator::GetContinuousPose3d | ( | bool | carriageFirst | ) | const |
Get the pose of each moving stage of a continuous elevator, for publishing to AdvantageScope as components of a robot model. A continuous elevator's stages move one at a time. Which moves first depends on how it is rigged: watch it move to see which it is.
- Carriage first: the carriage rises the whole of its travel first, then the stage below it, and so on out to the stage nearest the fixed stage. Going down, the stage nearest the fixed stage lowers first.
- Carriage last: the stage nearest the fixed stage rises the whole of its travel first, then the next, and so on out to the carriage. Going down, the carriage lowers first.
The stages are set with ElevatorConfig::WithStages().
- Parameters
-
carriageFirst True if the carriage moves first, false if it moves last.
- Returns
- Each moving stage's pose, relative to the robot, from the stage nearest the fixed stage to the carriage. The last is the carriage, GetPose3d().
- Exceptions
-
ElevatorConfigurationException if the stages are not set, or there are fewer than 2.
◆ GetHeight()
| wpi::units::meter_t yams::mechanisms::positional::Elevator::GetHeight | ( | ) | const |
Get the current carriage height from the motor encoder.
- Returns
- Current height in meters.
◆ GetName()
|
overridevirtual |
Get the human-readable name of this elevator.
Implements yams::mechanisms::SmartMechanism.
◆ GetPose3d()
|
overridevirtual |
Get the carriage's pose, for publishing to AdvantageScope as a component of a robot model: where the elevator is mounted, as set in its MechanismPositionConfig, moved up the elevator by its height, at the elevator's angle in its movement plane.
- Returns
- The pose of the carriage, relative to the robot.
Implements yams::mechanisms::SmartMechanism.
◆ Gte()
| wpi::cmd::Trigger yams::mechanisms::positional::Elevator::Gte | ( | wpi::units::meter_t | height | ) |
Trigger that fires while the elevator height is >= the given height.
- Parameters
-
height Reference height.
- Returns
- Trigger for the >= condition.
◆ IsNear()
| wpi::cmd::Trigger yams::mechanisms::positional::Elevator::IsNear | ( | wpi::units::meter_t | height, |
| wpi::units::meter_t | within = wpi::units::meter_t{0.01} |
||
| ) |
Trigger that fires while the elevator is within tolerance of a height.
- Parameters
-
height Reference height. within Tolerance.
- Returns
- Trigger for the near condition.
◆ Lte()
| wpi::cmd::Trigger yams::mechanisms::positional::Elevator::Lte | ( | wpi::units::meter_t | height | ) |
Trigger that fires while the elevator height is <= the given height.
- Parameters
-
height Reference height.
- Returns
- Trigger for the <= condition.
◆ Max()
|
overridevirtual |
Trigger that becomes true when the elevator is at or above its maximum configured height.
- Returns
- Trigger for the upper hard limit.
Implements yams::mechanisms::positional::SmartPositionalMechanism.
◆ Min()
|
overridevirtual |
Trigger that becomes true when the elevator is at or below its minimum configured height.
- Returns
- Trigger for the lower hard limit.
Implements yams::mechanisms::positional::SmartPositionalMechanism.
◆ Run() [1/2]
| wpi::cmd::CommandPtr yams::mechanisms::positional::Elevator::Run | ( | std::function< wpi::units::meter_t()> | height | ) |
Set the height of the elevator via a supplier.
- Parameters
-
height Supplier returning the desired height each loop.
- Returns
- CommandPtr that sets the elevator height, runs continuously.
◆ Run() [2/2]
| wpi::cmd::CommandPtr yams::mechanisms::positional::Elevator::Run | ( | wpi::units::meter_t | height | ) |
Set the height of the elevator.
- Parameters
-
height Height of the elevator to reach.
- Returns
- CommandPtr that sets the elevator height, runs continuously.
◆ RunTo() [1/2]
| wpi::cmd::CommandPtr yams::mechanisms::positional::Elevator::RunTo | ( | std::function< wpi::units::meter_t()> | height, |
| wpi::units::meter_t | tolerance = wpi::units::meter_t{0.01} |
||
| ) |
Command the elevator to a height from a supplier, then end when within tolerance.
The supplier is evaluated once when the command is created.
- Parameters
-
height Supplier for the target height. tolerance Acceptable error.
- Returns
- CommandPtr that ends once the elevator is near the target.
◆ RunTo() [2/2]
| wpi::cmd::CommandPtr yams::mechanisms::positional::Elevator::RunTo | ( | wpi::units::meter_t | height, |
| wpi::units::meter_t | tolerance = wpi::units::meter_t{0.01} |
||
| ) |
Command the elevator to a fixed height, then end when within tolerance.
- Parameters
-
height Target carriage height. tolerance Acceptable error.
- Returns
- CommandPtr that ends once the elevator is near the target.
◆ SetHeight()
| void yams::mechanisms::positional::Elevator::SetHeight | ( | wpi::units::meter_t | height | ) |
Directly command the elevator to a height setpoint (non-command, for use in periodic).
- Parameters
-
height Desired carriage height.
◆ SimIterate()
|
overridevirtual |
Advance the elevator's simulation by one loop iteration.
Implements yams::mechanisms::SmartMechanism.
◆ UpdateTelemetry()
|
overridevirtual |
Publish elevator telemetry to NetworkTables / SmartDashboard.
Implements yams::mechanisms::SmartMechanism.
◆ VisualizationUpdate()
|
overridevirtual |
Update the Mechanism2d ligament to reflect the current height.
Implements yams::mechanisms::SmartMechanism.
The documentation for this class was generated from the following file:
- /home/runner/work/YAMS/YAMS/yams/cpp/include/yams/mechanisms/positional/Elevator.hpp
